


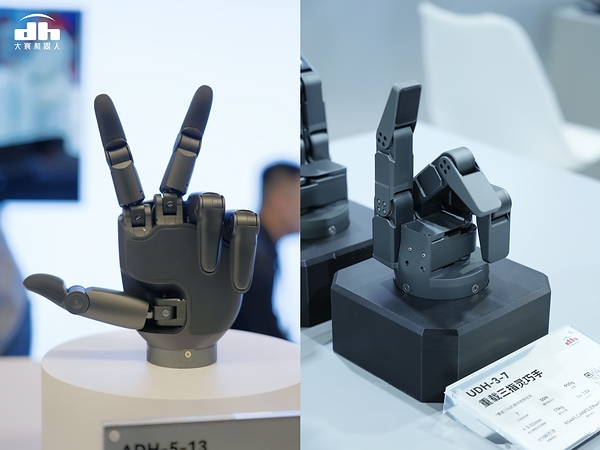
ADH-5-13 joins the deployment-focused UDH-3-7 and a portfolio of two-, three- and five-finger robotic end effectors
PITTSBURGH, Sept. 30, 2026 /PRNewswire/ — DH-Robotics today debuted the ADH-5-13, a five-finger dexterous hand with 13 independently controllable active degrees of freedom (DOF), at IROS 2026 in Pittsburgh. The company also demonstrated the UDH-3-7, its three-finger direct-drive dexterous hand, alongside a portfolio of two-, three- and five-finger end effectors for a range of gripping and manipulation tasks.


DH-Robotics showcases its fully direct-driven ADH-5-13 five-finger and UDH-3-7 three-finger dexterous hands at IROS 2026 in Pittsburgh, marking the global debut of the ADH-5-13.
The debut reflects DH-Robotics’ “Dexterity as Productivity” approach: matching hand architecture, sensing and control to the manipulation requirements of embodied AI research, teleoperation and robotic systems.
ADH-5-13: a five-finger platform for multi-finger manipulation
The ADH-5-13 uses an anthropomorphic five-finger configuration with 13 active DOF. The thumb, index finger and middle finger each have three DOF; the ring and little fingers each have two. The index and middle fingers also provide ±15° of lateral motion for a broader range of multi-finger poses.
At 735 g, the hand is designed to balance dexterity with system weight. DH-Robotics specifies a maximum lifting payload of up to 20 kg once an object is grasped.
The ADH-5-13 integrates fingertip tactile sensing and can accommodate additional sensing options, including electronic skin, six-axis force/torque sensors and vision-based tactile sensors. Sensors and individual modules can be replaced without dismantling the entire hand or a full finger, simplifying service and maintenance. According to DH-Robotics, this serviceable design improves maintenance efficiency by 300%, helping reduce downtime and operating and maintenance costs.
The hand’s fully direct-drive, backdrivable architecture provides independent control of all 13 active DOF. Dual magnetic encoders at each joint provide position feedback, and DH-Robotics specifies fingertip positioning repeatability of ±0.2 mm. The company says the architecture supports hybrid force/position control and compliant contact behavior in manipulation tasks.
UDH-3-7: strength, flexibility and a compact three-finger form factor
The UDH-3-7 is built around a streamlined three-finger configuration with seven active DOF. DH-Robotics specifies a maximum payload of 15 kg, maximum fingertip force of 50 N, positioning repeatability of ±0.02 mm and a design life of one million cycles.
The hand also uses a direct-drive, backdrivable design. Its thumb supports a 180° range of rotation and opposition, enabling different grasp configurations for objects with varied shapes and materials.
UDH-3-7 supports CAN FD, RS-485 and EtherCAT. Development tools support C++ and Python, while ROS 2 integration and workflows using Isaac and MuJoCo can help teams evaluate and integrate the hand in embodied AI systems.
A portfolio organized around the task
DH-Robotics positions its two-, three- and five-finger end effectors around distinct manipulation needs:
- Two-finger end effectors: general-purpose gripping and grasping.
- Three-finger dexterous hands: a balance of strength, dexterity and working space for manipulation.
- Five-finger dexterous hands: coordinated multi-finger manipulation and more complex dexterous tasks.
IROS attendees can see the portfolio at Booth #1008 through Sept. 30. The IROS 2026 conference runs Sept. 27–Oct. 1 in Pittsburgh.
About DH-Robotics
DH-Robotics develops robotic end effectors and precision motion-control components for industrial automation and embodied AI. Its portfolio includes electric grippers, dexterous hands, linear coil actuators, rotary grippers and servo electric cylinders. Learn more: https://en.dh-robotics.com/.

